Teaching two legs to walk
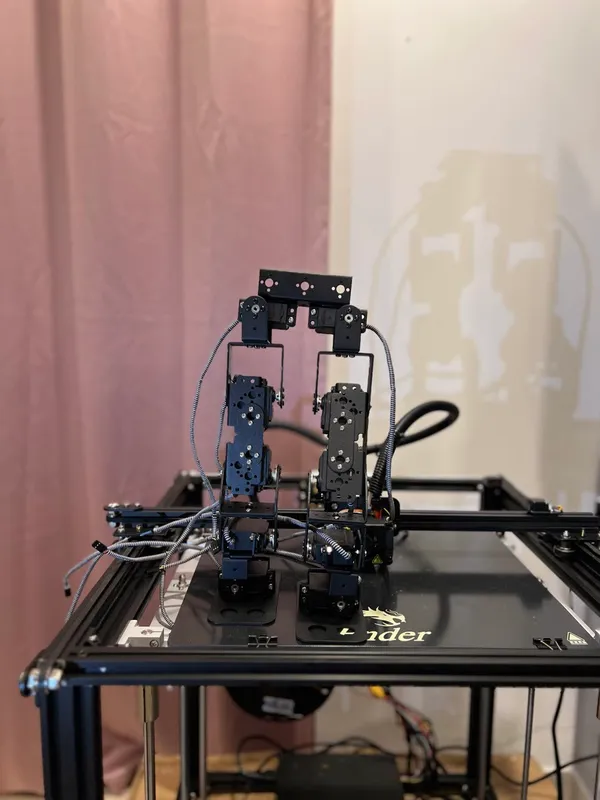
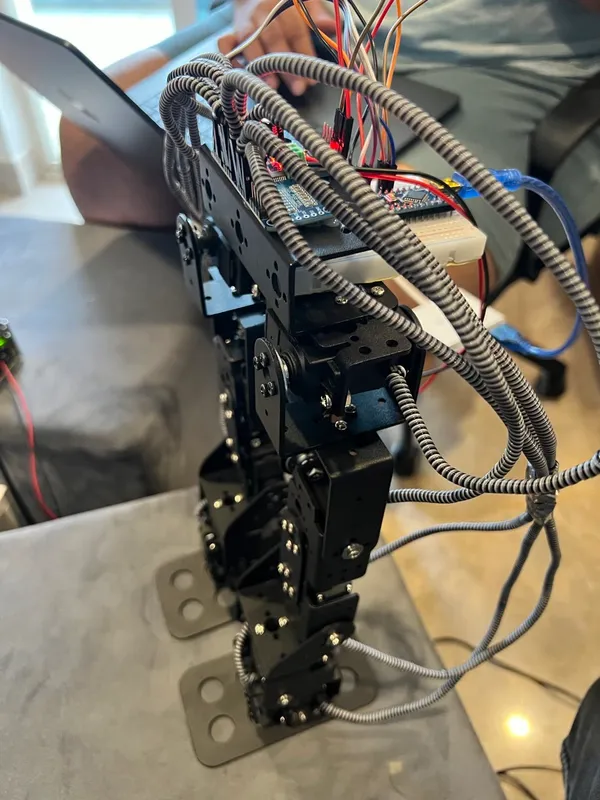
I started PhysicalAGI, an AI robotics company, and designed and prototyped its first system, a 17-DOF bipedal robot built for dynamic walking.
- Joints
- 17 degrees of freedom
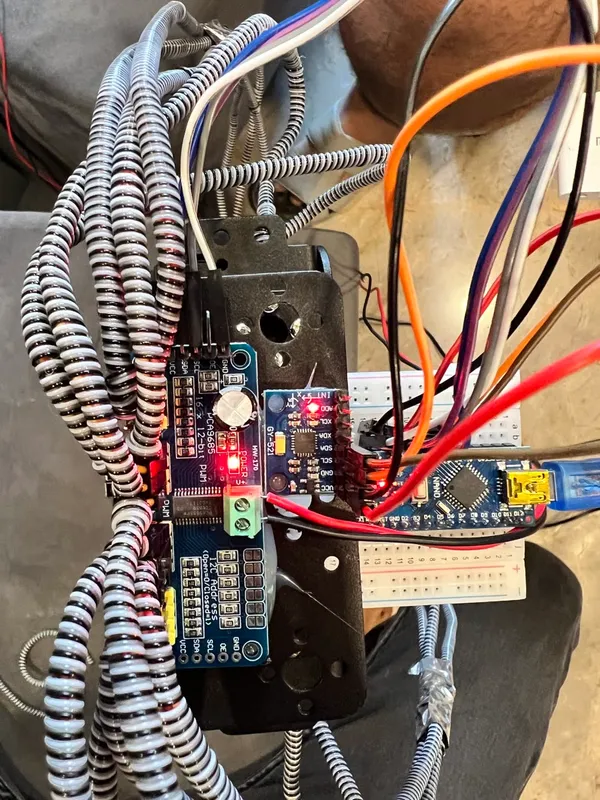
- Controller
- Arduino Nano
- Servo driver
- PCA9685
- Motion sensor
- MPU-6050
- Parts
- 3D-printed on an Ender
The problem
A walking robot is a control problem before it is an AI problem. In dynamic walking the body tips past the stance foot on every step, and the controller has to read the motion sensor and place the next foot in time to catch it.
How it was built
- CAD Modelled every bracket and servo to the millimetre, with real masses and joint axes.
- URDF Exported the model as links and joints, with limits and inertias, for the simulator and ROS to share.
- PyBullet Simulated stance and gaits first, so a bad gait broke in software, not on the bench.
- ROS Ran the stack as ROS nodes: gait, inverse kinematics, the IMU, and a bridge to the servos.
- Servos An Arduino Nano had the PCA9685 generate the servo pulses, and the MPU-6050 measured how the body tilted.
Walking is geometry
A gait is a path for each foot. Inverse kinematics turns each reachable point on that path into joint angles: the law of cosines gives the knee, then the hip, and the ankle keeps the sole level.
- hip
- knee
- ankle
Both segments have length L.
d = min(√(x² + y²), 2L)
θknee = 2 arccos(d / 2L)
θhip = atan2(x, y) + θknee / 2
θankle = θknee − θhip, so the sole stays level
What was hard
Precision. The simulator only knows the robot through the model exported from CAD, so every error in that model becomes an error in the physics.
- Inertia. A wrong mass or an impossible inertia makes the simulation unstable. PyBullet even ignores the CAD inertia unless you tell it to use it.
- Collisions. Parts whose collision shapes overlap get shoved apart on the first step.
- Joints. A joint placed slightly off moves where the foot lands, and a correct gait tips over.
So the model had to match the metal before any gait was worth testing.
Why it ended
In early 2024 my father had a severe cardiac arrest. He needed me close, full time, and so did my family. I chose taking care of them over building my startup, and wound PhysicalAGI down. I wrote about him here.